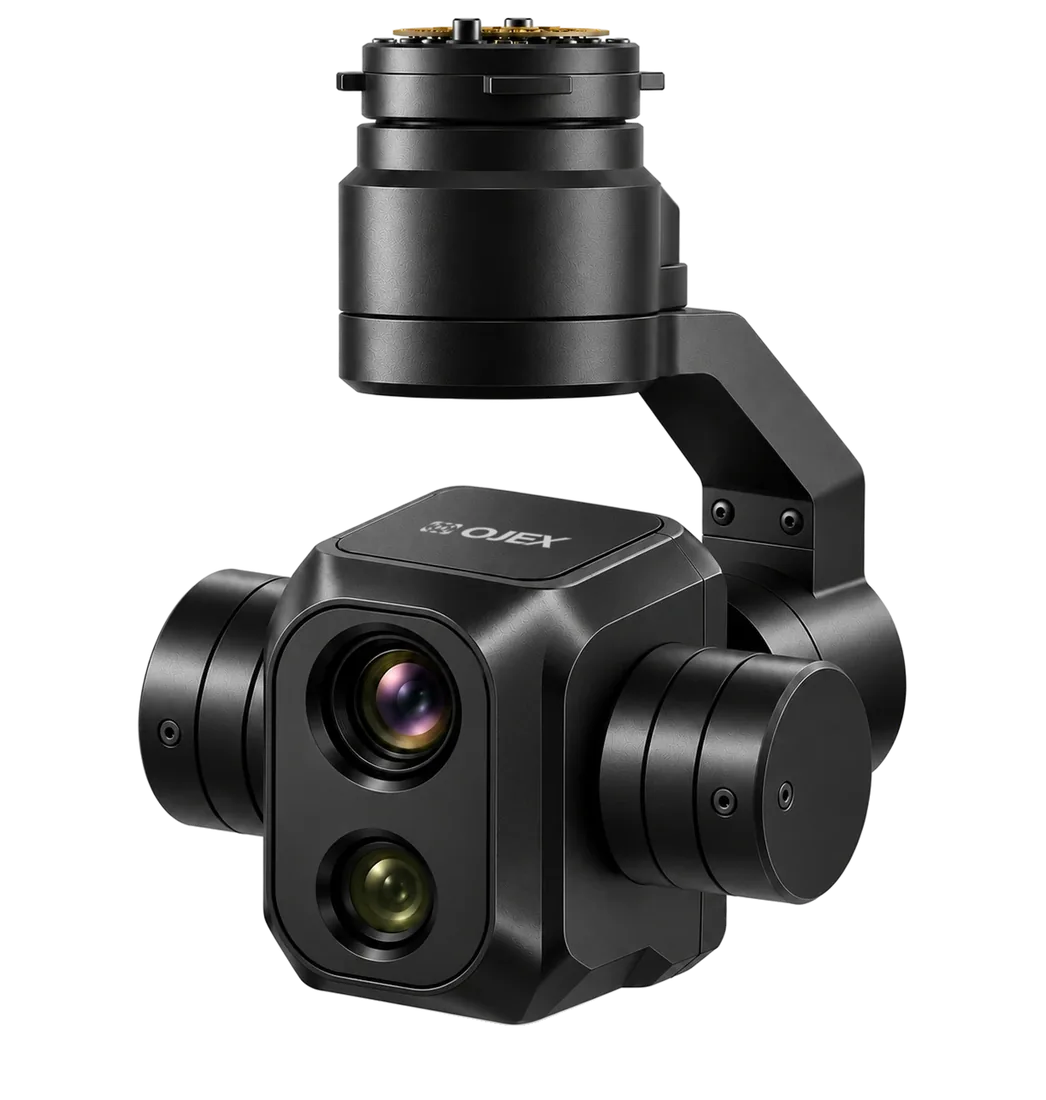
A three-axis stabilized dual-sensor payload for UAV observation and ISR missions, day and night. Integrates a 48MP visible camera and a 640×480 thermal camera on a direct-drive gimbal with brakes on all axes, with native ArduPilot integration via MAVLink Gimbal Protocol v2.
| Structure | 3-axis (Roll / Pitch / Yaw) · Direct-drive brushless motors, brake on all axes |
|---|---|
| Mechanical Range | Roll 120° · Pitch +20° ~ −90° · Yaw 240° |
| Max. Angular Speed | Pan ≥ 100°/s · Tilt ≥ 60°/s |
| Position Hold Error | ±0.02° |
| Operating Mode | Follow mode / Inertial stabilization mode (90–97% base-motion rejection) |
| EO Camera | 48MP CMOS · Output 1920×1080 / 30fps · HFOV 45° |
| IR Camera | Uncooled thermal, 640×480, 12 µm · 19 mm lens, HFOV 22.9° · 30fps |
| Gimbal Control | MAVLink Gimbal Protocol v2 (ArduPilot compatible) |
| Video Output | UVC / MIPI · Micro-coaxial connector |
| Supply Chain | 100% non-red, no PRC-origin components · Designed and manufactured in Taiwan |
E-Gimbal stabilizes video electronically in a 19×19 mm, 11 g package — no motors or bearings.